Optimizing Waste Streams: Using Computer Vision for High-Precision Sorting for Renewables & Environmental Services Industry is not mainly a camera purchase decision. It is an operating-model decision. A sorting system only creates value when it improves a measurable outcome: cleaner commodity streams, higher recovery of target material, safer handling of risky items, steadier throughput, or better data for #EnvironmentalManagementSystems.
Computer vision can identify, locate, and classify objects moving through a waste stream. But the difficult work starts after recognition. Facilities must determine what accuracy is sufficient, how to handle uncertain items, whether a robotic picker or air jet can act fast enough, and how the model will stay reliable as packaging and feedstock change.
Table Of Contents
- Why High-Precision Sorting Requires More Than Image Recognition
- Designing A Computer Vision Sorting System
- Measuring Performance, Economics, And Deployment Risk
- Key Takeaways
- Frequently Asked Questions
- Resources And Citations
Why High-Precision Sorting Requires More Than Image Recognition
The Operational Goal Is A Better Output Stream
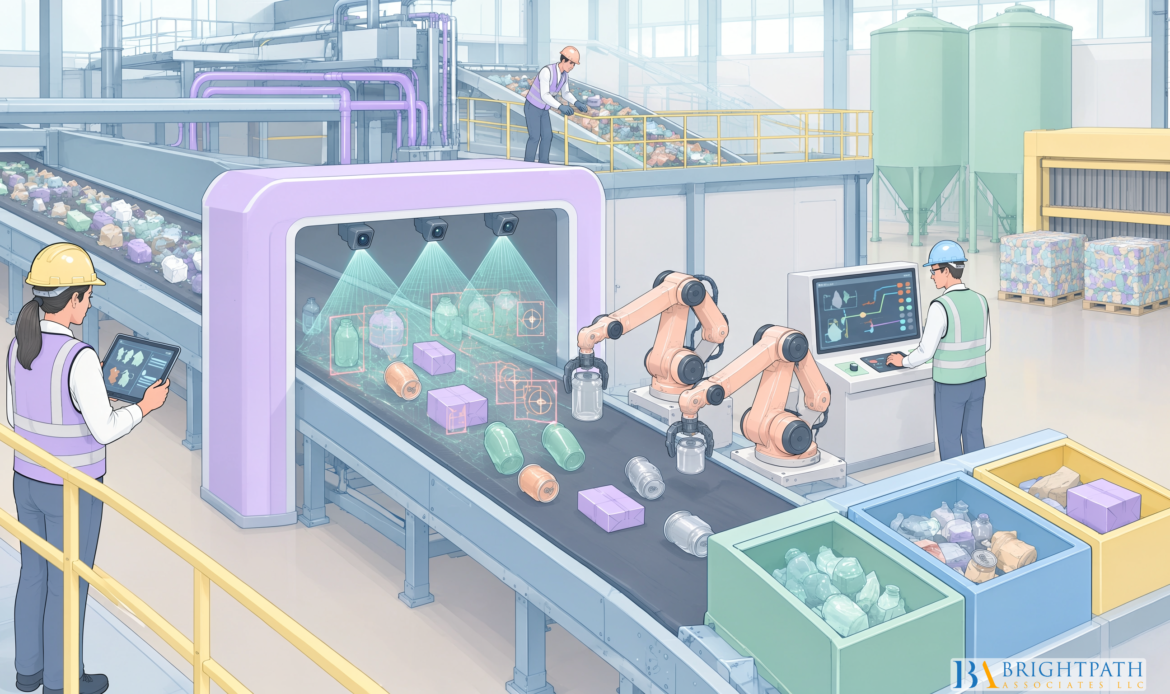
Computer vision uses cameras and machine-learning models to detect visual features, classify material, and estimate an item’s location on a conveyor. In a material recovery facility, that information can guide a robot, air jet, diverter, or human quality-control station.
The point is not to automate every decision. The point is to make the right decision at the right point in the line.
For example, a facility may use vision to remove visible contamination from a PET stream after primary separation. Another may use it upstream to identify recoverable film, bulky contamination, or hazardous items before they disrupt downstream equipment. These are different use cases with different tolerance for error.
A model that identifies a bottle correctly but triggers an actuator too late has not improved sorting. Likewise, a system that protects bale purity by rejecting every uncertain item may send too much valuable material to residue. High-precision sorting is therefore a balance among classification performance, material presentation, actuation timing, and end-market specifications.
Computer Vision And Optical Sorting Serve Different Roles
#ConventionalOptical sorting often relies on sensor signals such as near-infrared response, color, shape, and material characteristics. Computer vision adds image recognition, object detection, and segmentation. It can be especially useful when the facility needs information about an item’s form, location, label, visible condition, or relationship to other objects.
| Capability | Conventional Optical Sorting | Computer Vision | Combined Approach |
|---|---|---|---|
| Primary signal | Material and spectral characteristics | Visual appearance and object location | Multiple sensor signals assessed together |
| Best fit | High-volume, relatively well-presented streams | Object-specific decisions and quality control | Complex or high-value recovery lines |
| Key limitation | May have limited context about object condition | Can struggle with occlusion and visual ambiguity | Higher integration and maintenance complexity |
| Typical action | Air ejection or mechanical separation | Robot guidance, air ejection, alerts, or auditing | Layered separation and quality assurance |
Computer vision should usually be viewed as a complement, not an automatic replacement, for existing optical and mechanical systems. The strongest design question is: Where does visual context solve a decision that current equipment handles poorly?
A proposed SBIR autonomous sorting platform illustrates this direction. It combines computer vision with semi-supervised learning and domain adaptation to organize diverse waste objects in cluttered environments for downstream sorting. The concept is also designed for decentralized preprocessing in a compact footprint. That is promising, but it should not be interpreted as proof of universal MRF-scale performance or return on investment.
Waste Stream Composition Is A Deployment Variable
The same model can perform differently across facilities because the incoming stream is not constant. Residential loads differ from commercial loads. Seasonal shifts affect packaging, moisture, and organics. Local collection rules change the mix of containers, films, cartons, and non-target material.
This is often called domain shift. It occurs when the model’s training images no longer resemble real operating conditions. Changes in lighting, camera angle, conveyor speed, packaging graphics, residue buildup, or feedstock composition can all reduce performance.
We recommend treating site data as part of the capital plan, not an afterthought. Before selecting a vendor or building a custom model, collect representative images across operating conditions:
- Capture images across shifts, seasons, weather conditions, and feedstock sources.
- Include clean items, damaged items, overlapping items, and heavily contaminated items.
- Label the material classes that affect actual business decisions rather than every visible object.
- Preserve samples from low-confidence detections for later review and retraining.
- Re-test performance after collection-program changes or major packaging shifts.
This matters for environmental services leaders because the model becomes part of the facility’s operating discipline. It requires ownership, data governance, maintenance planning, and clear escalation rules.
Designing A Computer Vision Sorting System
Start With The Conveyor, Not The Algorithm
A reliable system begins with material presentation. Cameras need a useful view of each item. If objects are piled together, shadowed, wet, or moving too quickly for the shutter and illumination design, even a strong model will face avoidable uncertainty.
A practical architecture has five linked elements:
| System Element | Decision It Supports | Common Failure Mode | Design Response |
|---|---|---|---|
| Camera and lens | Captures usable item detail | Motion blur or blind areas | Match frame rate, shutter speed, and field of view to belt speed |
| Lighting | Creates stable visual conditions | Glare, shadows, reflective packaging | Use controlled lighting and monitor fixture degradation |
| Edge computing | Runs inference near the line | Network delay or dropped connection | Keep time-sensitive decisions local where feasible |
| Conveyor tracking | Predicts item position at actuation | Timing mismatch | Synchronize encoder data with image timestamps |
| Actuation | Removes or redirects material | Missed picks or incorrect ejections | Validate reach, response time, and object spacing |
Edge inference is often appropriate when a decision must happen within the short travel time between camera and actuator. Cloud processing may still be useful for data storage, model training, fleet monitoring, and reporting. The two approaches are not mutually exclusive.
For a simple example, consider a container detected 1.5 meters before an air jet. The system must calculate its travel time from conveyor speed, account for the location of the object on the belt, classify it with enough confidence, and trigger the jet during the correct interval. A highly accurate image model will still fail operationally if its response arrives after the object has passed the #EjectionZone.
Segmentation Matters When Items Touch Or Overlap
Classification answers, “What is in this image?” Object detection answers, “What is present and roughly where?” For mixed waste, instance segmentation can add a useful layer by separating individual objects at the pixel level.
That matters when a crushed bottle overlaps a bag, or when several containers are touching. A user-described mixed-waste computer vision prototype combined object detection, image augmentation, and segmentation for bottles, containers, bags, and paper. It is a practitioner example rather than independently validated facility evidence, but it points to a real engineering issue: waste rarely arrives as neat, isolated objects.
Segmentation is not always worth its added computing and annotation burden. It is most useful when overlap is a major source of missed recovery or contamination. For a well-spread stream where items are clearly separated, simpler detection may be enough.
Choose The Actuator Around The Material And Business Case
Vision identifies an object. The separation method determines whether the identification becomes an operational result.
• Robotic picking can be useful for discrete, higher-value objects, bulky contamination, or material that requires selective handling.
• Air jets can suit fast-moving, lighter, well-spaced items when timing is tightly controlled.
• Mechanical diversion may fit broader category separation where individual object precision is less critical.
• Human quality control remains useful for safety-critical, unusual, or low-confidence decisions.
A documented Masotina retrofit case study from Terex ZenRobotics describes a facility that combined automated sorting with optical, mechanical, and manual sorting. The broader lesson is practical: hybrid lines can be more realistic than a full-replacement strategy, particularly where existing equipment, floor space, and downtime limits shape the project.
Retrofits demand careful site engineering. Leaders should map power capacity, network reliability, guarding, emergency stops, dust exposure, access for maintenance, and line downtime before making performance promises. Greenfield facilities can place cameras, lighting, and actuators around the intended material flow. Retrofits often require compromises, which should be priced into the #BusinessCase.
Measuring Performance, Economics, And Deployment Risk
Accuracy Is Not A Single Number
A model’s general “accuracy” does not tell executives whether it will improve a commodity stream. Sorting decisions should be measured at the class level and at the line level.
| Metric | What It Measures | Why Executives Should Care |
|---|---|---|
| Precision | Share of selected items that truly belong in the target class | Affects contamination and output purity |
| Recall | Share of target items successfully identified | Affects recovery and missed value |
| Purity | Share of output stream that meets the intended material specification | Affects bale quality and buyer acceptance |
| Recovery | Share of target material captured from the incoming stream | Reveals value lost to residue or other streams |
| Throughput | Material or items processed over time | Determines whether the system fits the operating line |
| Availability | Time the system is ready to operate | Exposes maintenance and downtime risk |
The central tradeoff is between purity and recovery. Raising a confidence threshold can reduce false positives and make the output cleaner. But it can also reject borderline target items, lowering recovery.
Suppose a system identifies clear PET containers confidently but hesitates on wet, crushed, label-covered containers. Setting a very high threshold may protect purity but send many recoverable items to residue. A lower threshold may improve recovery but introduce contaminants. There is no universal setting. The right threshold depends on the target commodity, downstream quality controls, market requirements, and cost of error.
An Arizona State University embedded prototype reported more than 80% classification accuracy for paper, plastic, and metal under varying lighting conditions in a limited project environment. Its real-time embedded recycling classification project is useful evidence that lightweight models can operate under variable lighting, but it should not be used as a benchmark for full-scale MRF purity, recovery, or throughput.
Build A Business Case Around Avoided Failure, Not Just Labor
The available evidence does not establish a standard U.S. payback period for computer-vision waste sorting. Capital cost, maintenance, energy use, labor effects, and commodity revenue vary too widely by line design and feedstock to justify a universal estimate.
A sound business case should quantify the specific decisions the technology changes:
- Revenue from additional recovered material, using conservative commodity assumptions.
- Reduced contamination or disposal cost, where measured at the relevant output stream.
- Avoided downtime caused by problematic materials or manual intervention.
- Labor redeployment requirements, including supervision, maintenance, quality control, and data review.
- Costs of cameras, lighting, computing, integration, safety systems, spare parts, labeling, retraining, and vendor support.
Computer vision also contributes to broader operational intelligence. Images and classifications can show where contamination enters the stream, which items recur, and whether collection or commercial customers need targeted education. That connects sorting data to economic sustainability strategies for environmental services rather than treating automation as an isolated #EquipmentPurchase.
Plan For Exceptions, Safety, And Model Drift
A sorting line needs an explicit policy for items the model cannot classify confidently. Batteries, sharps, e-waste, pressurized containers, black plastics, flexible films, transparent packaging, and wet material can present different kinds of risk. Some are hard to see. Others are visually recognizable but difficult to actuate safely.
A sensible escalation design may include three paths:
- High confidence: Automatically sort the item.
- Medium confidence: Route the item to a secondary quality-control step when practical.
- Low confidence or safety concern: Flag, isolate, or send to trained human review under site safety procedures.
A robotics practitioner discussion proposed exactly this type of human handling for low-confidence detections and edge cases. It does not establish a validated threshold, but the operating principle is sound: staged automation can reduce risk while the facility gathers evidence about real failure modes.
This is also where computer vision may support advanced monitoring systems for environmental safety. The camera system can become an additional observation point, but it does not replace safety controls, training, guarding, or hazardous-material procedures.
For leadership teams, the talent implication is clear. Projects need more than an equipment buyer. They may require leaders who can connect recycling technology, maintenance reliability, safety, data governance, procurement, and commercial quality commitments. That blend can be difficult to assess through a conventional recruitment process focused only on prior job titles. A disciplined executive search process may be justified when the role has direct accountability for operational transformation, capital deployment, or compliance risk.
Key Takeaways
What Leaders Should Act On Now
• Define the waste-stream problem before selecting a vision platform. Prioritize a measurable outcome such as purity, recovery, contamination reduction, safety, or throughput.
• Test performance using site-specific feedstock. Vendor demonstrations cannot fully represent local material composition, weather, contamination, or conveyor conditions.
• Measure precision, recall, purity, recovery, throughput, and availability separately. One accuracy percentage is not enough for an investment decision.
• Set confidence thresholds deliberately. Higher thresholds may improve purity while reducing recovery.
• Design a hybrid operating model. Computer vision, optical equipment, mechanical systems, robotics, and trained human review can each have a defined role.
• Budget for model maintenance. Packaging, lighting, feedstock, and collection programs change, and the system needs a process for monitoring and retraining.
• Treat leadership capability as part of implementation risk. Technology projects fail when ownership across operations, safety, maintenance, and data is unclear.
Advanced pollution control strategies provide a useful adjacent framework: #EnvironmentalPPerformance improves when facilities connect equipment decisions to measurable controls, accountability, and continuous monitoring.
Frequently Asked Questions
What Is Computer-Vision Waste Sorting?
Computer-vision waste sorting uses cameras and machine-learning models to identify, classify, locate, or segment objects in a waste stream. The system can guide an air jet, robot, diverter, alert, or quality-control worker. Its value depends on whether it improves a defined sorting decision under real conveyor conditions.
Can Computer Vision Distinguish Plastic Resins?
Sometimes, but visual appearance alone may not reliably identify every resin, especially when containers are dirty, black, crushed, covered by labels, or visually similar. Computer vision can complement near-infrared and other sensing methods. Facilities should validate performance against the specific resin classes and packaging formats they need to separate.
How Accurate Must A System Be Before It Improves Economics?
There is no single threshold. A system can be useful with imperfect classification if it improves a high-cost decision, such as removing dangerous contamination or recovering a valuable material from a quality-control line. Evaluate precision, recall, purity, recovery, throughput, and availability against the current baseline and cost of error.
Should Inference Run At The Edge Or In The Cloud?
Use edge inference when timing is critical and a decision must occur immediately near the conveyor. Cloud systems may support centralized storage, model training, reporting, and fleet oversight. Many facilities will benefit from a hybrid design that keeps actuation decisions local while using cloud tools for longer-term analysis.
Is Robotic Picking Better Than Air-Jet Ejection?
Neither is universally better. Robotic picking can suit discrete, higher-value, bulky, or difficult-to-handle items. Air jets can suit lighter, well-spaced objects at higher speeds. The choice depends on item weight, spacing, belt speed, target value, safety, and required precision.
How Should A Facility Handle Low-Confidence Detections?
Create a documented escalation path. High-confidence items can be sorted automatically. Uncertain items may be routed to secondary inspection, while possible batteries, sharps, e-waste, or hazardous material should follow site-specific safety controls. Save uncertain images for review because they can reveal model drift and future training needs.
How Often Must Models Be Retrained?
There is no verified standard interval. Retraining should be triggered by measured performance decline, new packaging formats, camera changes, lighting changes, altered collection rules, or meaningful feedstock shifts. Routine audit samples are more reliable than waiting for a major quality failure.
Resources And Citations
• SBIR.gov — SBIR Phase II: Autonomous waste sorting platform for decentralized pre-processing. https://www.sbir.gov/portfolio/2466969
• Arizona State University — Real-Time MCU-Based Smart Recycling Bin with Embedded Computer Vision. https://forge.engineering.asu.edu/furiproject/real-time-mcu-based-smart-recycling-bin-with-embedded-computer-vision/
• Terex ZenRobotics — Masotina case study. https://www.terex.com/zenrobotics/case-studies/masotina
• Reddit r/robotics — Using machine learning, computer vision, and automation to rethink waste sorting. https://www.reddit.com/r/robotics/comments/10w7ttf/using_machine_learning_computer_vision_and/
• Reddit r/computervision — Real-Time Waste Sorting/Classification using CV. https://www.reddit.com/r/computervision/comments/1sblkne/realtime_waste_sortingclassification_using_cv/
BrightPath Associates resource: 2030 vision report on environmental services
Find your next leadership role in Renewable Energy and Environment Industry today!
Stay informed with the latest insights on Renewable Energy Environment Industry!